Research
Projects I have contributed to. Highlighted is my main ongoing work.
Humanoid Wall Climbing with Compliant Spines
In progress
Shixuan Zhao,
Sam Xie,
Hao Li,
Hayi Zhao,
Justin Chen,
Teo Ren,
Sirui Chen,
Zhanpeng He,
Qi Wu,
C. Karen Liu,
Mark R. Cutkosky
In preparation
webpage
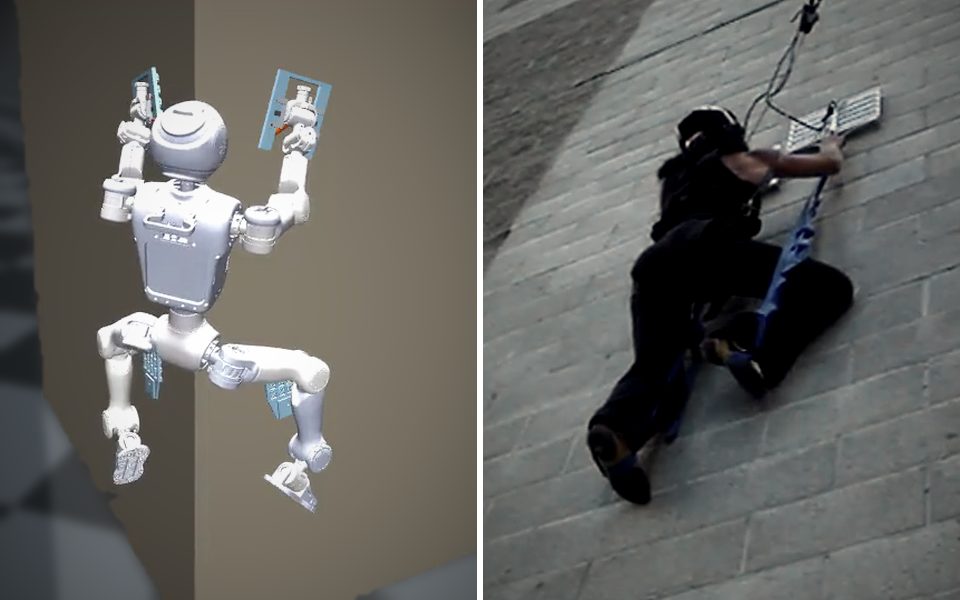
Teaching a humanoid to climb vertical walls on micro-spine palms. Its whole-body motions are
generated with a probabilistic model of spine contact rather than taken from human demonstrations.
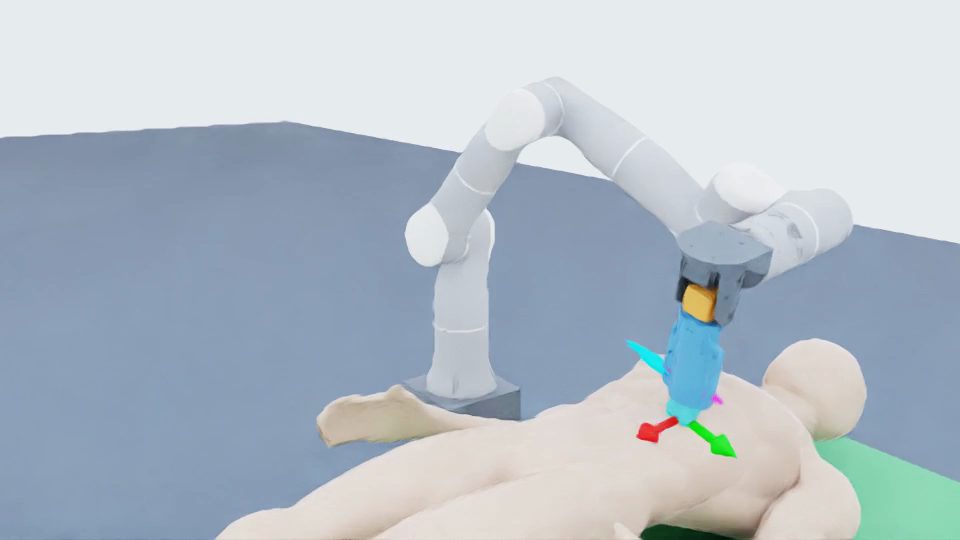
DistalShift: How Distal Redundancy Shapes Robot Arm Motion and Joint Loading
Tian-Ao Ren*,
Tongyu Wang*,
Shixuan Zhao,
Rohan Karunaratne,
Tao Zhang,
Rachel Thomasson,
Mark R. Cutkosky
Submitted to ICRA 2027
webpage|
pdf
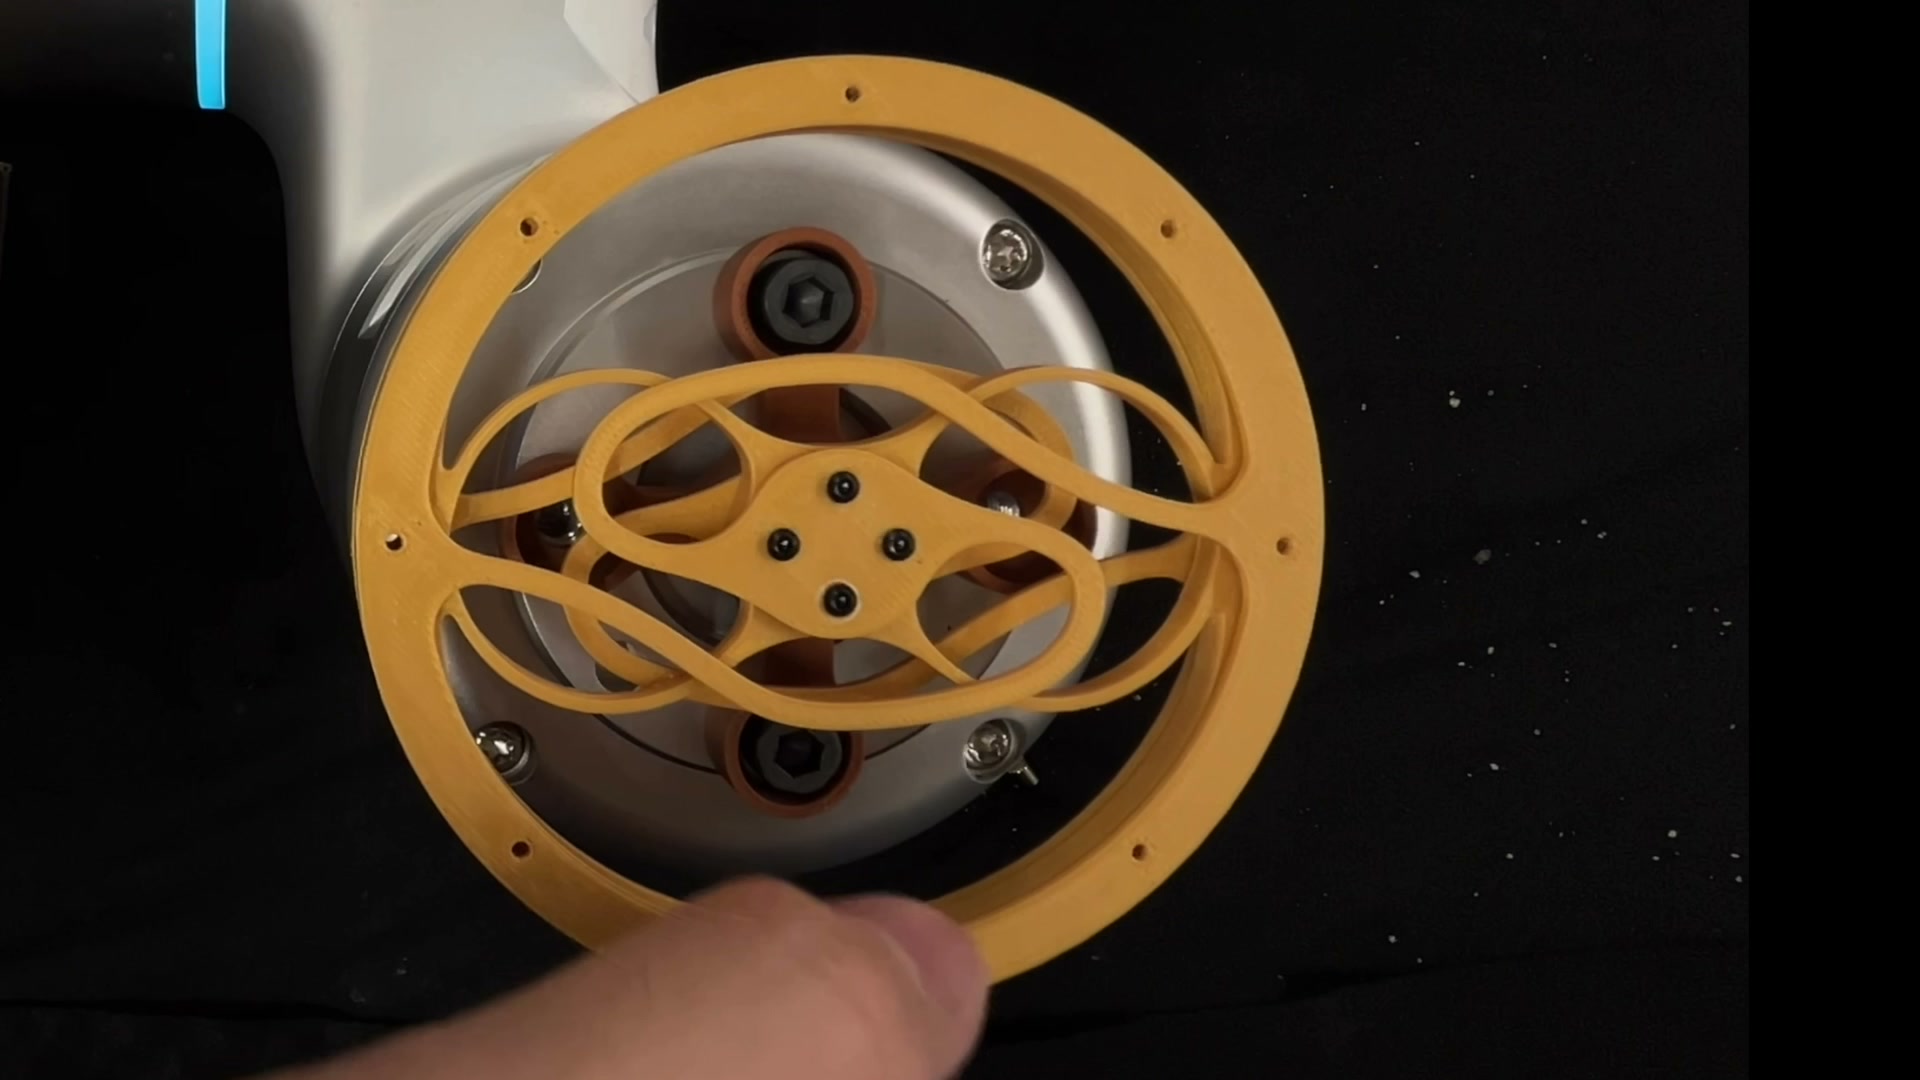
A compact 2-DoF add-on wrist reorients an ultrasound probe right at the tool, so the
7-DoF arm holding it sweeps much less space and carries less joint load.
I built the controller pipeline that integrates wrist and arm control into reusable,
robust primitives within a manager-based architecture.
* Equal contribution
Education
- Stanford University, M.S. in Mechanical Engineering (2025 – present)
- The University of Arizona, B.S. in Mechanical Engineering (2021 – 2025)
- Hebei University of Technology, B.Eng. in Mechanical Engineering (2021 – 2025)